LEROBOT BY HUGGING FACE
LeRobot arm kits and parts.
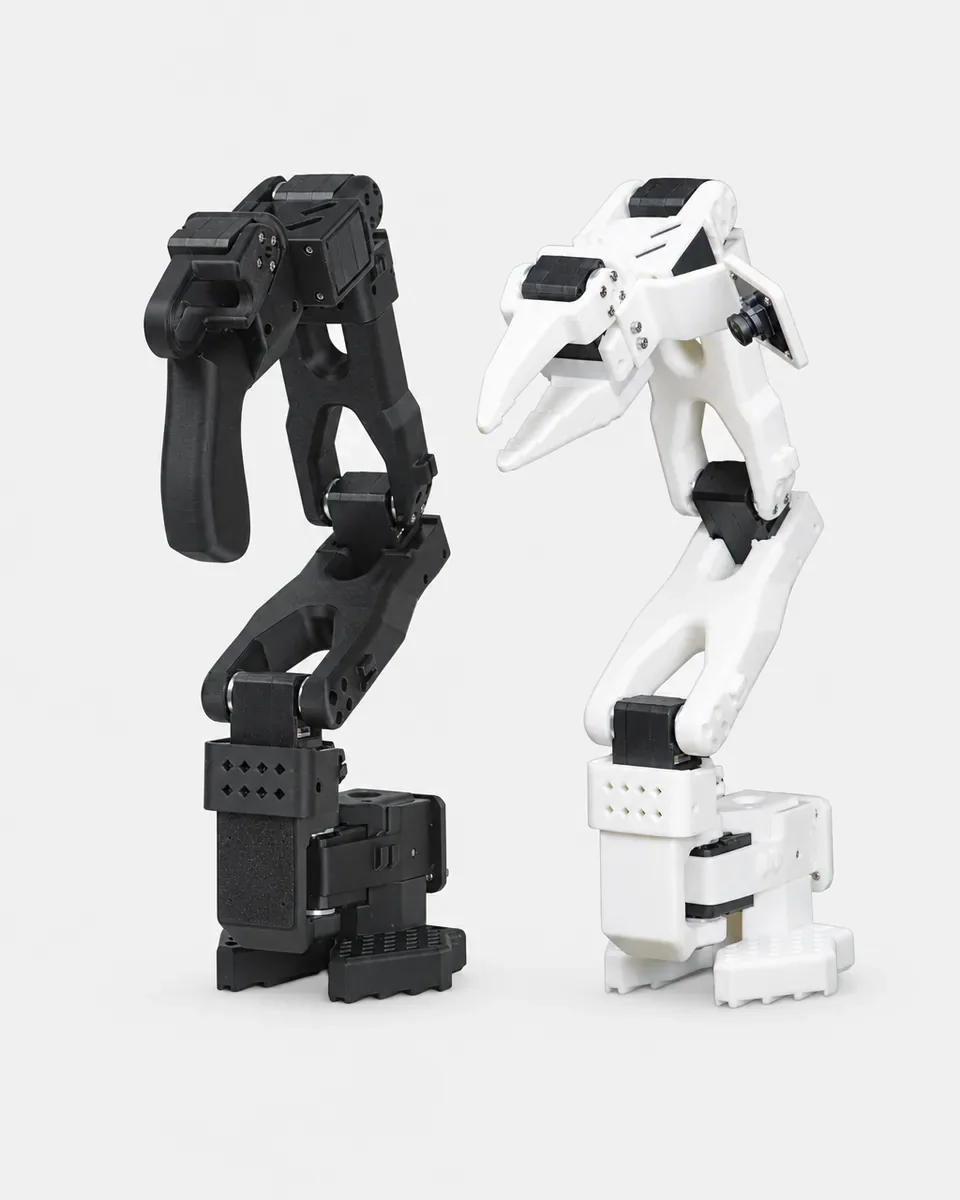
Gather the hardware for an open-source LeRobot build in one place: SO-101 (SO101) six-axis leader and follower arms, Feetech STS3215 bus servos, a bus servo adapter and the LeKiwi mobile base. Pick the parts, follow the tutorial, record demonstrations and train a policy.
Shipping and taxes included · Confirm stock and your delivery address before paying.
From parts to a trained policy
A LeRobot build has five stages. Each one links to the matching part of our step-by-step tutorial.
-
Choose the parts
Pick a leader and a follower arm, the servos and the bus adapter. Controller, power supply, clamps and cameras are confirmed with your quote.
Open this step → -
Assemble and calibrate
Give every motor its ID, assemble both arms and calibrate them so the follower copies the leader joint by joint.
Open this step → -
Teleoperate
Move the leader by hand and let the follower repeat the motion, first without and then with cameras.
Open this step → -
Record demonstrations
Record episodes of the task you want to teach. The motion and camera images become the training data.
Open this step → -
Train and run a policy
Train an ACT policy on a GPU, then run it on the follower so the arm repeats the task by itself.
Open this step →
LeRobot kits and parts
Match the arm, bus, power supply and controller to your build. Every arm is a 6-DOF open source robot arm built from 3D-printed parts and STS3215 servos. Prices are in US dollars; ask us if you need a part that is not listed.
 View specifications
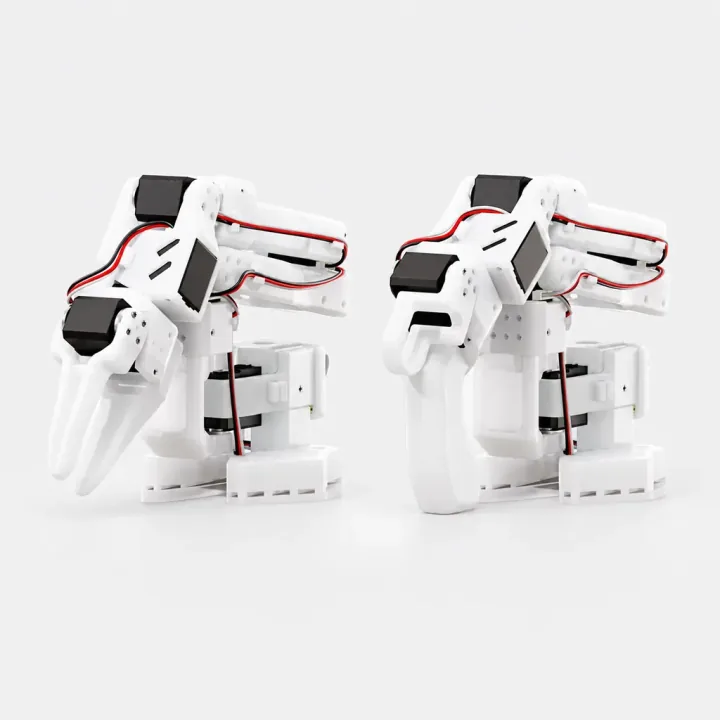
LeRobot SO-101 DIY robot arm kit
Robot arms
Leader DIY kit · 7.4 V Request priceFollower DIY kit · 12 V Request price
 View specifications
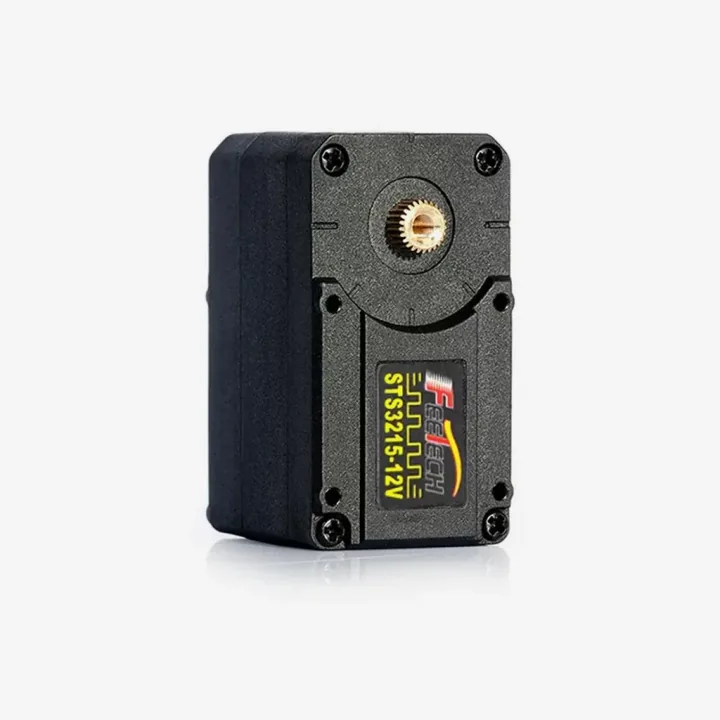
Feetech STS3215 servo (7.4 V / 12 V) for SO-101
Serial servos
C001 · 7.4 V · 1/345 US$99.00 · each Shipping and taxes includedC018 · 12 V · 1/345 US$110.00 · each Shipping and taxes includedC044 · 7.4 V · 1/191 US$99.00 · each Shipping and taxes includedC046 · 7.4 V · 1/147 US$99.00 · each Shipping and taxes included
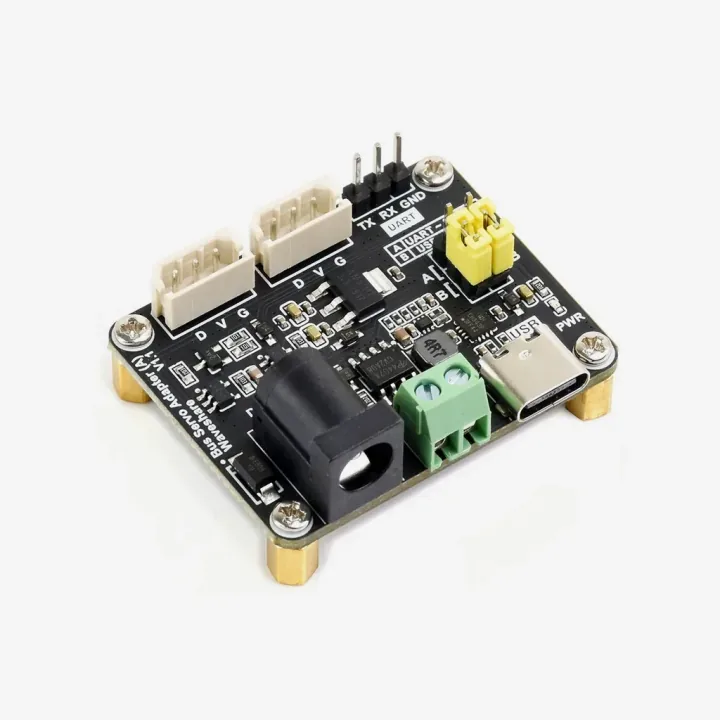
Waveshare Bus Servo Adapter (A) for STS3215 servos
Servo control boards
US$27.00 · each Shipping and taxes included
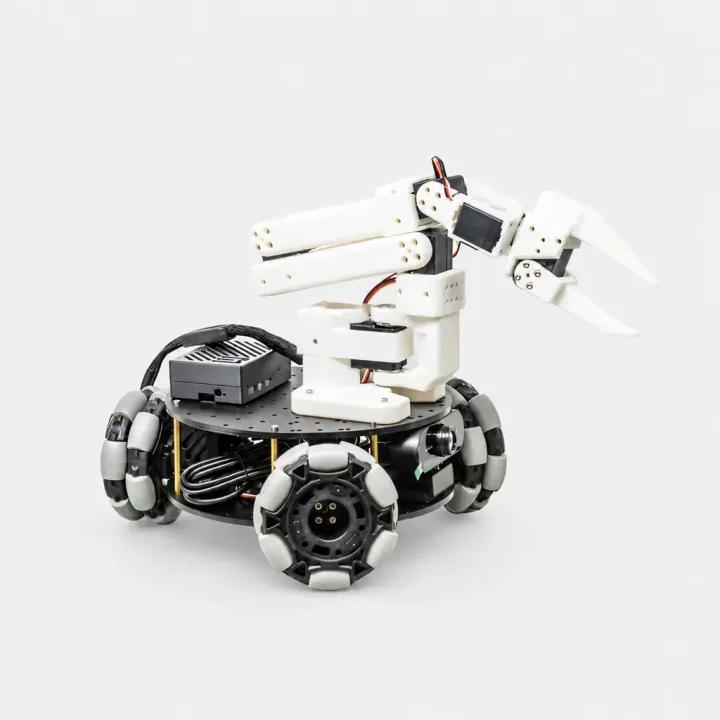 View specifications
LeKiwi robot mobile base kit (LeRobot)
Mobile robotics kits
DIY chassis · 100 mm omni wheels · no controller Request priceAssembled chassis + SO-101 Follower · no controller Request price
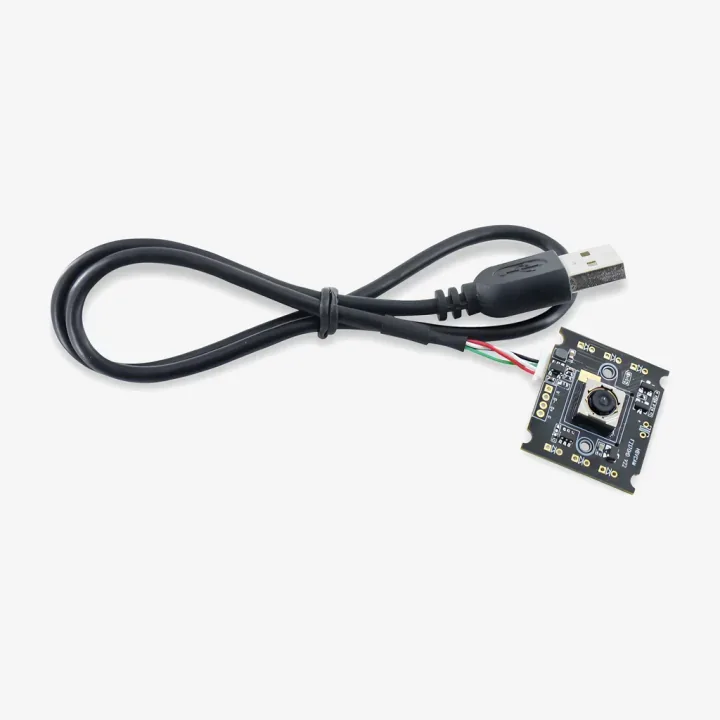 View specifications
SO-101 robot arm camera kit (1080p USB wrist camera)
Cameras
Wrist camera kit · 86° US$79.00 · each Shipping and taxes includedWrist camera kit · 95° US$89.00 · each Shipping and taxes includedFixed scene camera kit · 86° US$119.00 · each Shipping and taxes includedTwo-camera kit · 86° US$189.00 · each Shipping and taxes included
 View specifications
Orbbec Gemini 335L / 336L / 305 depth camera
Cameras
Gemini 335L Request priceGemini 336L Request priceGemini 305 Request price
 View specifications
Feetech STS3215-C066 virtual servo for the SO-101 leader
Serial servos
C066 · one servo US$52.00 · each Shipping and taxes includedC066 · six for one leader arm US$309.00 · per pack of 6 Shipping and taxes included
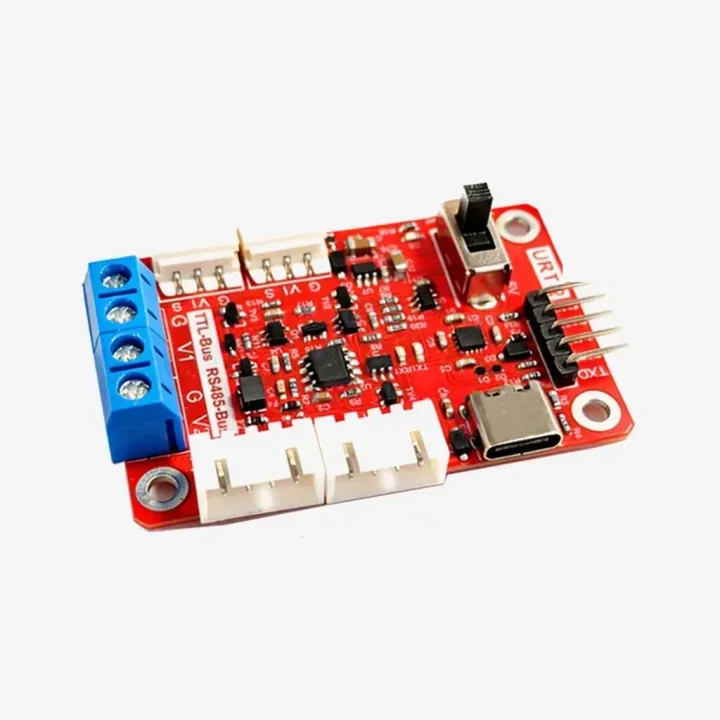
Feetech URT-2 serial bus servo debug board
Servo control boards
US$45.00 · each Shipping and taxes included
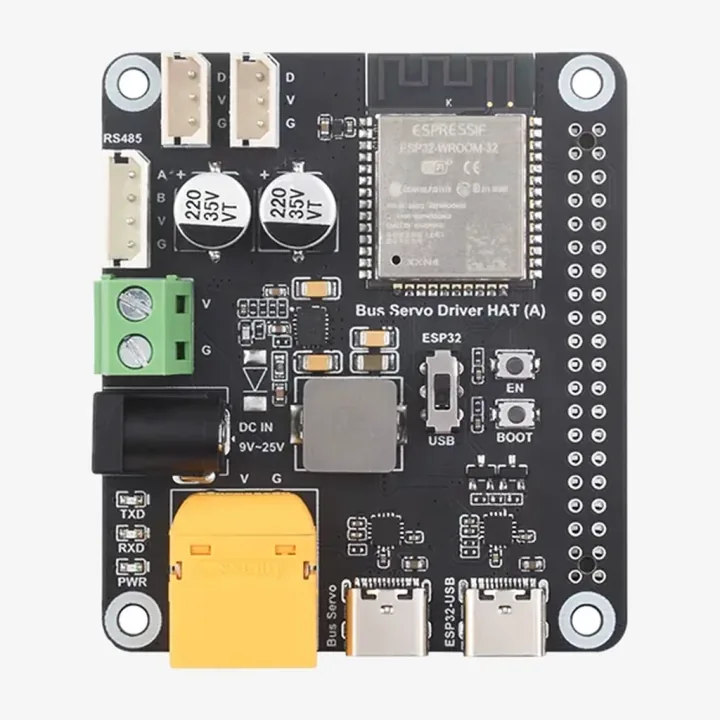
Waveshare Bus Servo Driver HAT (A) with ESP32
Servo control boards
US$100.00 · each Shipping and taxes included
 View specifications
Waveshare 5264 3-pin bus servo cables (pack of 6)
Cables
300 mm · 6 cables US$12.00 · per pack of 6 Shipping and taxes included900 mm · 6 cables US$19.00 · per pack of 6 Shipping and taxes included3 × 300 mm + 3 × 900 mm US$16.00 · per pack of 6 Shipping and taxes included
 View specifications
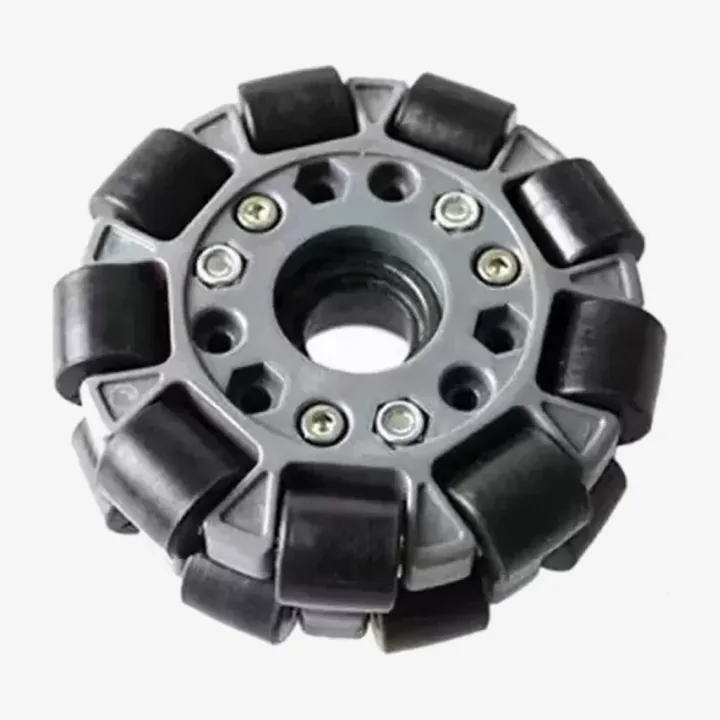
100 mm omni wheel for LeKiwi robots
Mobile robotics parts
One wheel US$110.00 · each Shipping and taxes includedOne wheel + 3D-printed coupler and screws US$128.00 · each Shipping and taxes included
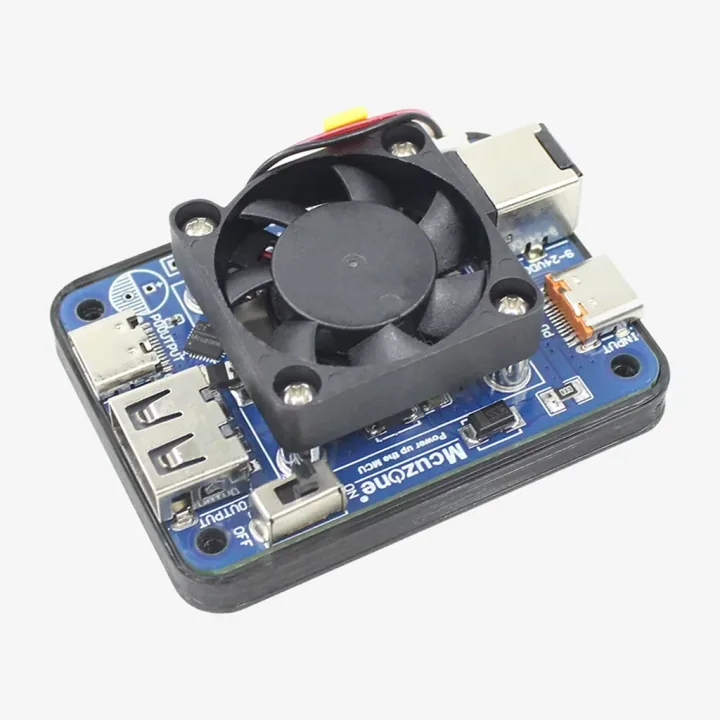
9–24 V to 5 V 5 A power module for Raspberry Pi 5
Mobile robotics parts
US$67.00 · each Shipping and taxes included
 View specifications
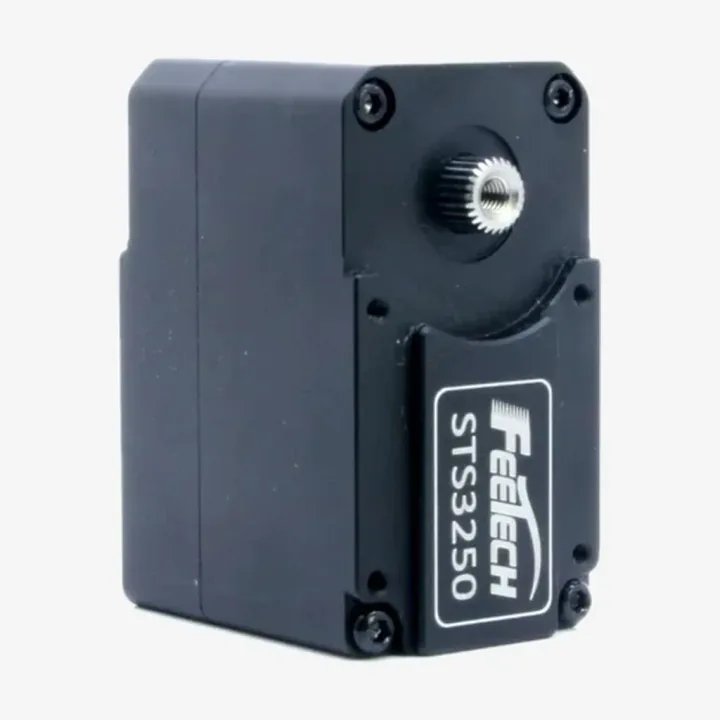
Feetech STS3250 50 kg·cm servo (12 V)
Serial servos
STS3250 · 12 V US$79.00 · each Shipping and taxes includedSTS3250 · 12 V + URT-1 debug board US$95.00 · each Shipping and taxes included
Guides for your build
LeRobot SO-101 tutorial
Step by step: install LeRobot, assemble, calibrate, record, train and run the SO-101 and LeKiwi.
02 ↗Reinforcement learning for robotics
LeRobot learns from demonstrations. Reinforcement learning learns by trial and error in simulation: see how it trains a biped robot to walk.
03 ↗SO-101 robot arm simulator
Free SO-101 browser simulator: automatic pick and place with inverse kinematics, six joint controls and local experiment records. No physical arm required.
LeRobot parts questions
What is the difference between the Leader and the Follower arm?
The Leader is the arm you move by hand and uses 7.4 V servos. The Follower copies it and uses 12 V servos. A full setup needs one of each, and each arm is selected separately.
What else do I need besides the arm kits?
A servo controller board, a power supply for each arm, clamps and cameras. Use the power supply that matches the servo voltage of each arm, and confirm the exact items with your quote.
Do I need a GPU?
Teleoperation and recording do not. Training the ACT policy used in our tutorial does need one. A laptop-class GPU is enough, and a rented GPU also works.
Which LeRobot version does the tutorial follow?
The commands match LeRobot v0.7.0. LeRobot changes quickly, so compare the flags with the documentation for the version you install.
ALSO FROM US
Want a robot that walks?
Microduck Robot is an open-source biped robot duck kit built around Arduino UNO Q and 15 serial servos. Assemble it, calibrate it and control it from a browser.
