Both kits use an Arduino Uno Q and 15 serial servos. Plan to assemble the robot, configure its servos and calibrate the joints before its first walk.
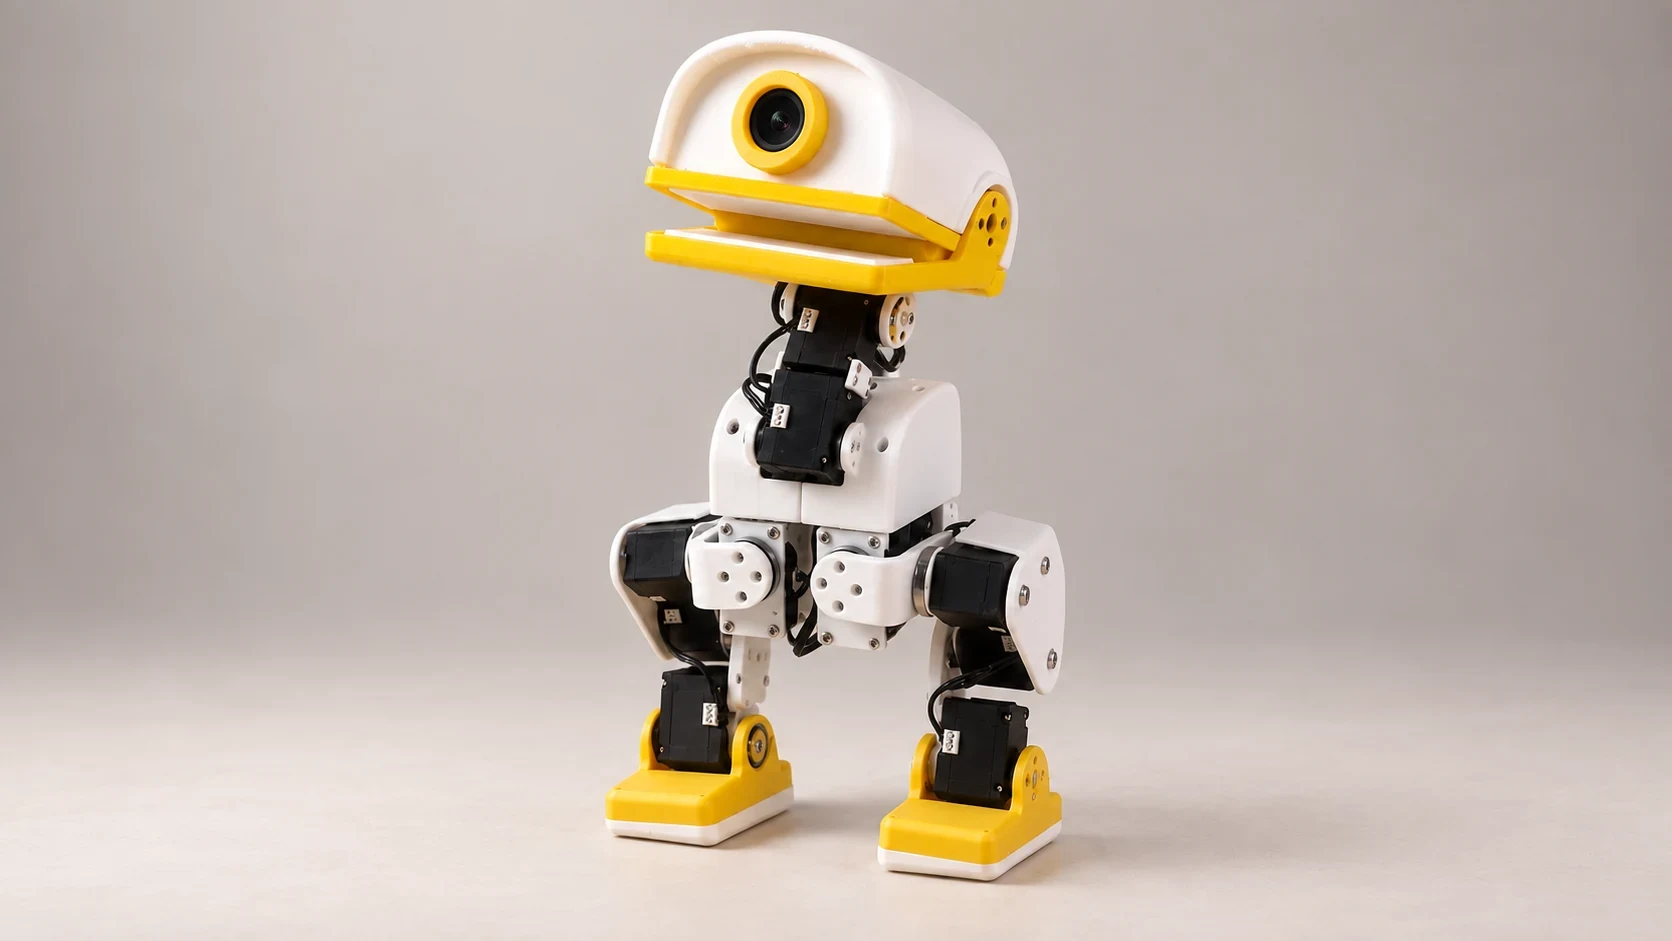
Illustration of the assembled camera-equipped kit.
Full kit
The documented full kit adds audio, a camera and a ToF distance sensor to the shared motion platform. These modules use the matching runtime for sensing and audio.
Assembly and calibration are required. Confirm which printed parts, cables and power accessories are supplied with your quote so you know what to prepare separately.
The basic kit covers biped movement, browser control and servo calibration. Its documented parts list covers the controller, expansion board, 15 servos and the associated hardware.
Print the shell separately using the matching STL files, then assemble and calibrate the robot. Check the quoted list to see which cables, fasteners and power accessories you need to supply.