Closed-loop control for a NEMA 17 stepper
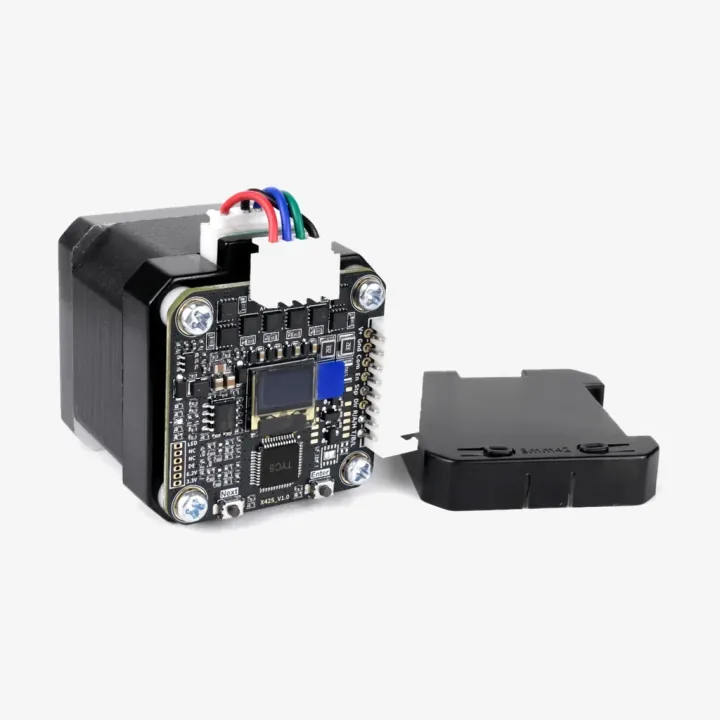
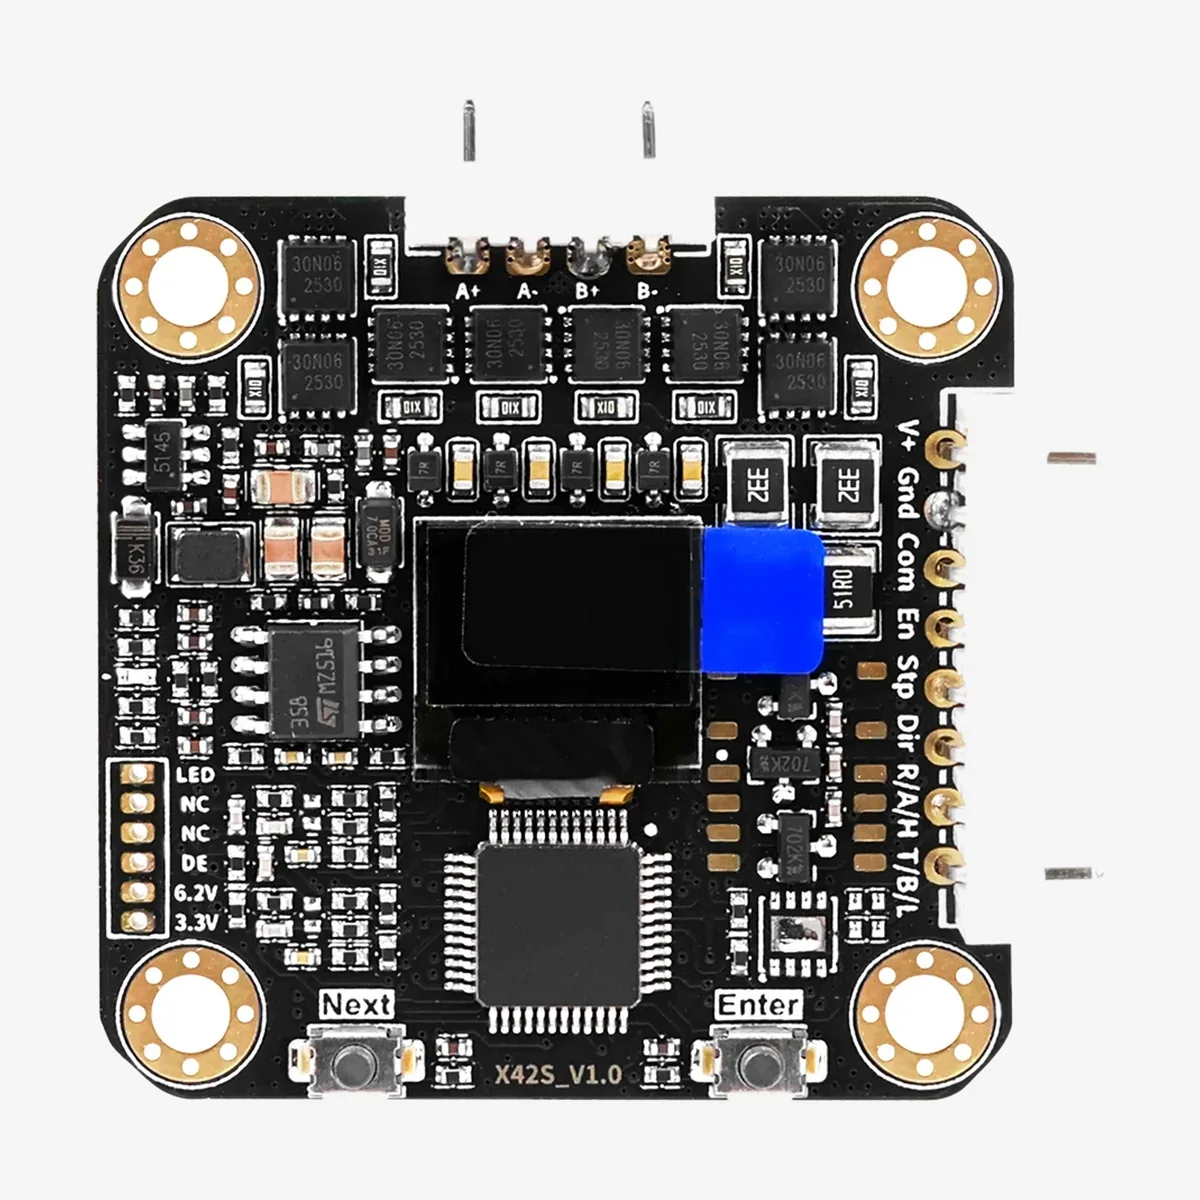
The X42S board mounts on the back of a 42 mm stepper and reads the shaft with a 14-bit magnetic encoder, so the motor does not lose steps. It accepts step/direction pulses like an ordinary driver and can also be commanded over TTL serial (A version) or CAN (C version).
- Supply: 10–29 V DC, at least 3 A; up to 5 A motor current.
- Modes: torque, speed and position control, synchronous commands for several motors, trapezoidal acceleration, homing and limits.
- Speed: 0.1 to over 3000 rpm; step pulses up to 300 kHz.
- Protocols: the maker's own protocol, Modbus and DMX512; firmware can be updated over USB-to-RS485 or CAN.
- On the board: an OLED display for angle, error and pulse count, and two buttons.
In the box
Motor options: the board fitted to a 40 mm motor, a 3 cm motor cable and a 50 cm 8-pin cable. Driver kit: the board, four M3 × 40 screws, four spacers, a 5 × 2.5 mm radial magnet for the motor shaft, a plastic housing, a motor cable and an 8-pin cable. The kit needs a motor with a rear shaft for the magnet.
Specifications
- Supply
- 10–29 V DC, 3 A or more
- Encoder
- 14-bit magnetic
- Control
- Pulse/direction plus TTL serial or CAN; torque, speed and position modes
- Speed
- 0.1 to over 3000 rpm; pulses up to 300 kHz
- Current
- Up to 5 A
- Motor
- 40 mm NEMA 17 in the motor options
- Included
- Board on motor, motor cable, 8-pin cable (motor options)
Compatibility checks
- Choose the CAN version for chaining several axes, TTL for a single microcontroller.
- The driver kit includes a radial magnet that must be fitted to your motor's shaft.
