Microduck Robot●microduck-robot.com

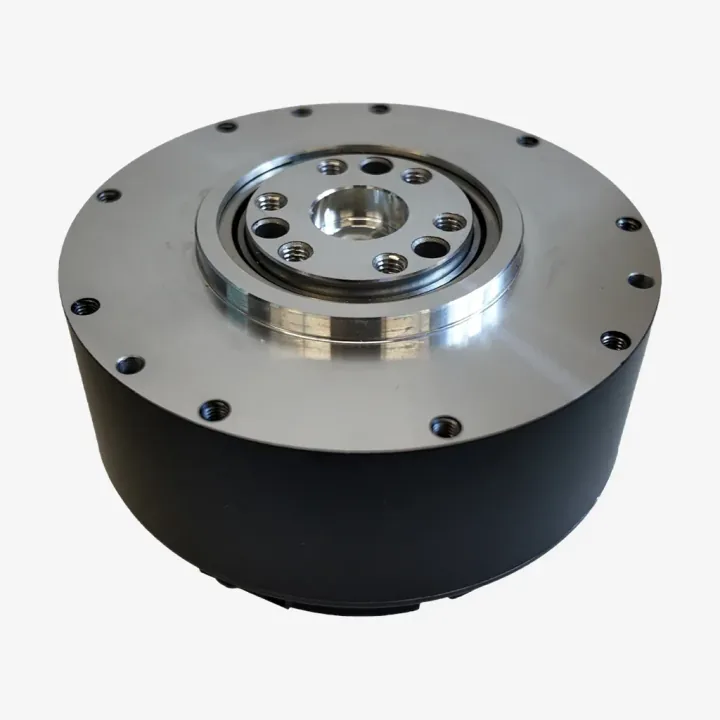
RobStride 02 joint actuator (17 N·m peak)

Joint motors

RobStride 02 joint actuator
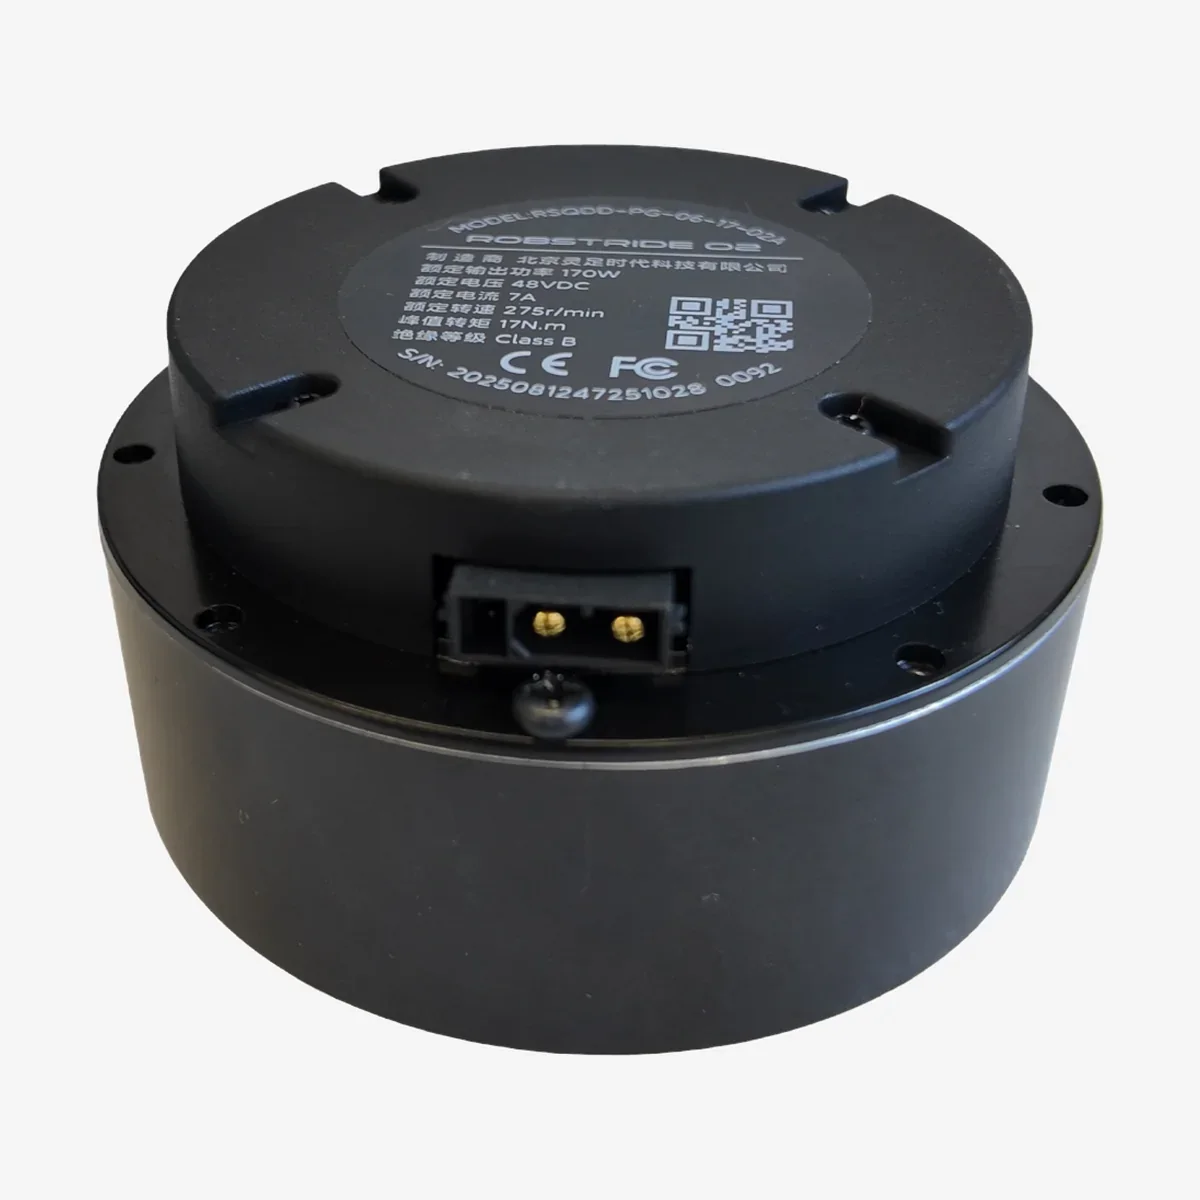
  • RobStride 02 rear cover and connector; the visible label reads 24VDC

Order options

Actuator

US$199.00 · each Shipping and taxes included

Actuator + CAN-to-USB module

US$215.00 · each Shipping and taxes included

A compact actuator for legged and humanoid robots: motor, FOC driver and a 7.75:1 reducer in a 400 g unit with two 14-bit encoders and 17 N·m peak torque.

What the RobStride 02 is

A three-in-one joint actuator for legged and humanoid robots: motor, FOC driver and a 7.75:1 reducer in a 400 g unit, with two 14-bit magnetic encoders and one bus input and one output for chaining.

Performance

  • Torque: 6 N·m rated, 17 N·m peak; about 10 s at 17 N·m and about 100 s at about 11 N·m according to the overload curve.
  • Speed: 315 rpm without load, 275 rpm at rated load (±10 %).
  • Supply: 48 V rated, 24–60 V range; 7 A rated and 23 A peak current.
  • Motor constants: torque constant 1.22 N·m/A rms, phase resistance 0.58 Ω.
  • Environment: −20 to 50 °C in use; CE marked.

The supplier does not list what is in the box. The option with the CAN-to-USB module lets you configure the actuator from a computer.

Specifications
Torque
6 N·m rated, 17 N·m peak
Speed
315 rpm no load, 275 rpm at rated load
Supply
48 V rated, 24–60 V range
Reducer
7.75:1
Encoders
2 × 14-bit magnetic
Bus
1 Mbps, one in and one out for daisy-chaining
Size and weight
Ø78.5 × about 41.5 mm, 400 g
Compatibility checks
  • Plan a 24–60 V supply that can deliver the peak current of every motor on the bus.
  • The option with the CAN-to-USB module is the easiest way to configure it from a computer.
  • What is in the box is not listed by the supplier; ask us if you need mounting parts.
  • Version needs confirmation: the reference photo label reads 24VDC, while the listed nominal specification is 48 V. Confirm the electrical version of the selected option in the quote; the photo does not verify that it is the same version.

Robot motors and reducers →

BEFORE YOU ORDER

Get the right part the first time

Start with the part you are replacing, then compare the model, connections and package below.

What should I check before choosing this part?
  • Plan a 24–60 V supply that can deliver the peak current of every motor on the bus.
  • The option with the CAN-to-USB module is the easiest way to configure it from a computer.
  • What is in the box is not listed by the supplier; ask us if you need mounting parts.
  • Version needs confirmation: the reference photo label reads 24VDC, while the listed nominal specification is 48 V. Confirm the electrical version of the selected option in the quote; the photo does not verify that it is the same version.
Which version or package should I select?
  • Actuator · each
  • Actuator + CAN-to-USB module · each
Compare order options →
Which specifications should I compare?
Torque
6 N·m rated, 17 N·m peak
Speed
315 rpm no load, 275 rpm at rated load
Supply
48 V rated, 24–60 V range
Reducer
7.75:1
Encoders
2 × 14-bit magnetic
Bus
1 Mbps, one in and one out for daisy-chaining
Size and weight
Ø78.5 × about 41.5 mm, 400 g
Compare order options ↑

Build notes & feedback

Used this part in a build? Tell us your exact model, selected option and what did or did not fit.

Share your experience ↗
Contact us