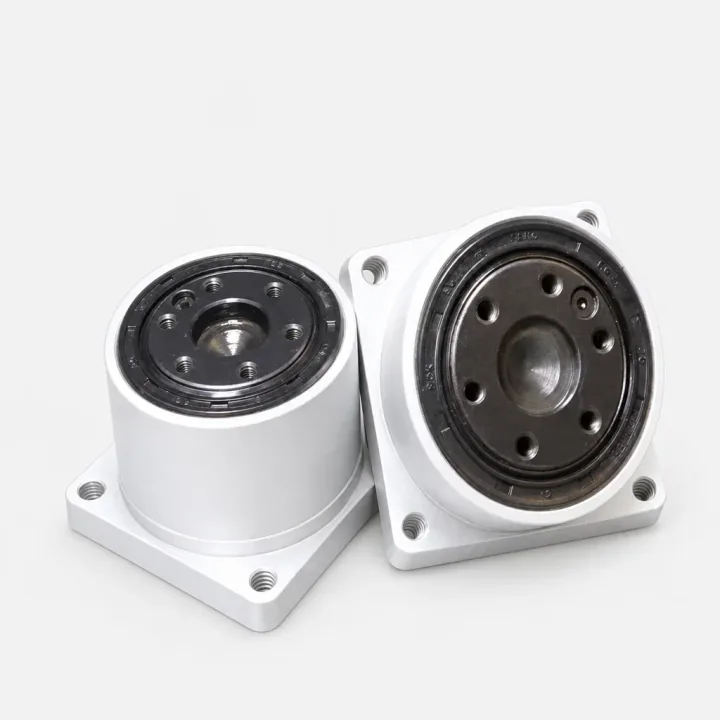
A strain-wave reducer for small robot joints
A size-11 harmonic reducer that bolts to the face of a 42 mm (NEMA 17) stepper. Harmonic reducers give high ratios in a short, light package, which is why desktop robot arms use them in the shoulder and elbow.
- Rated torque at 2000 rpm input: 2.2 N·m at 30:1, 3.5 N·m at 50:1, 5.0 N·m at 100:1.
- Peak start/stop torque: 4.5, 8.3 and 11 N·m; momentary maximum 8.5, 17 and 25 N·m.
- Input speed: 3500 rpm average, 8500 rpm maximum.
- Output: flange (MINIF11) or keyed shaft (MINIS11); coaxial layout.
- Weight: about 177 g (flange) or 200 g (shaft).
The supplier does not publish backlash or positioning accuracy. Only the reducer is included.
Specifications
- Ratios
- 30:1, 50:1 or 100:1 (flange), 50:1 (shaft)
- Rated torque
- 2.2 / 3.5 / 5.0 N·m at 30 / 50 / 100:1
- Momentary maximum
- 8.5 / 17 / 25 N·m at 30 / 50 / 100:1
- Input speed
- 3500 rpm average, 8500 rpm maximum
- Weight
- About 177 g (flange), 200 g (shaft)
- Input
- Fits 42 mm (NEMA 17) steppers
Compatibility checks
- Backlash and precision are not published for this reducer; ask us before ordering for precision work.
- Check your motor's shaft diameter against the reducer's input before ordering.
